Automated Facility
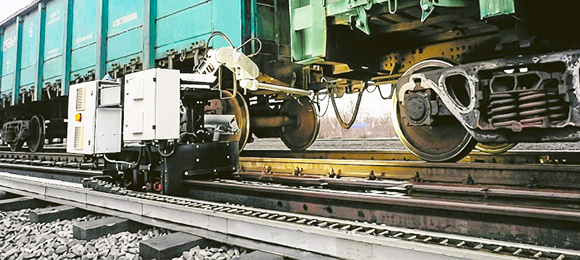
In July 2026, the Chelyabinsk-Glavny station successfully completed the trial operation of a robotic manipulator for automated car uncoupling. The tests confirmed the system’s operability and marked another step in the development of automated sorting technologies on the railway.
The tests were conducted as part of the Digital Railway Station project, which aims to introduce advanced technical solutions into railway infrastructure. The robot mounted on a mobile platform is capable of moving along a separate rail track laid along the marshalling yard.
One of the main features of the facility is the ability to operate synchronously with a moving train. The manipulator is capable of uncoupling cars at speeds of up to 10 km/h. During its trial operation, the system performed over 6,500 uncouplings. During testing, the robot maintained stable operation under various sorting modes and confirmed its suitability for use in high-intensity sorting conditions.
The station is currently preparing for acceptance testing. To achieve this, it is planned to equip all sorting tracks with robotic uncouplers. In the future, similar systems may be introduced at other major railway stations in Russia.